Projects
Autonomous Systems & Planning
Fall 2025
Minimum Lap Time Autonomous Racing Stack in AutoDrive Simulator
Developed reactive control and explored LiDAR, IMU, and wheel-encoder state estimation (EKF, SLAM, and an MLP estimator) for an autonomous racing stack in the AutoDRIVE simulator.
Key Result In simulation, the LiDAR-based reactive controller completed 10 consecutive collision-free laps on the Qualification Track; the team qualified in the AutoDRIVE RoboRacer Sim Racing qualification round.
Spring 2025
Multi-Step Deep Koopman for Vehicle Control in Frenet Frame
Embedded a Python deep-Koopman vehicle model in MATLAB/Simulink for trajectory-tracking MPC of a high-fidelity CarSim vehicle.
Implementation Cross-language Python–Simulink MPC integration with the CarSim-modeled vehicle; the work was presented at IROS 2025.
2024
Path-Planning and Collision Avoidance: Neural Network Approach
Studied learning-based path planning by reproducing Neural A* and U-Net–based planners and analyzing encoder–decoder variants.
Benchmark Reproduced key published results and benchmarked the architectures in PyTorch; proposed modifications for dynamic and multi-agent navigation.
Summer 2023 – Summer 2024
Path-Planning and Collision Avoidance of Ground Vehicles
Developed nonlinear and linearized MPC controllers in Julia for constrained vehicle racing and collision avoidance, including a dynamic-bicycle demonstration with six stationary obstacles.
Key Result In a 25 s closed-loop simulation, nonlinear MPC with a six-state dynamic bicycle model completed 2.29 laps past six stationary obstacles, with all 250 MPC updates accepted and no physical contact.
Control, Dynamics & Estimation
Fall 2025
Optimal Modified Feedback Strategies in LQ Games under Control Imperfections
Analyzed how execution errors in one player's feedback Nash strategy affect the other player's performance, and developed a disturbance-aware compensation law for finite-horizon LQ games.
Key Result In a simulated two-cart system, compensated feedback reduced Player 1's cost by 10.7% and integrated squared error by 41.3% relative to uncompensated feedback under the same actuator lag.
2024
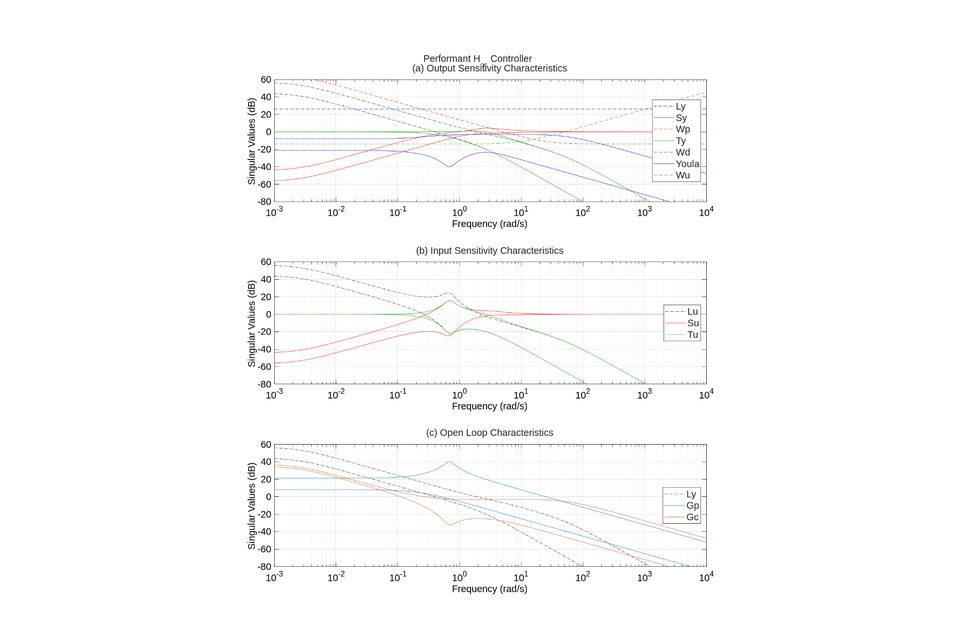
MIMO Optimal Robust Control for Fixed-Wing UAVs
Compared classical and robust control designs for fixed-wing UAV dynamics in MATLAB/Simulink.
Evaluation Designed and compared PID, Youla, and H∞ controllers and analyzed performance and robustness under model uncertainty with frequency-domain tools.
Spring 2023
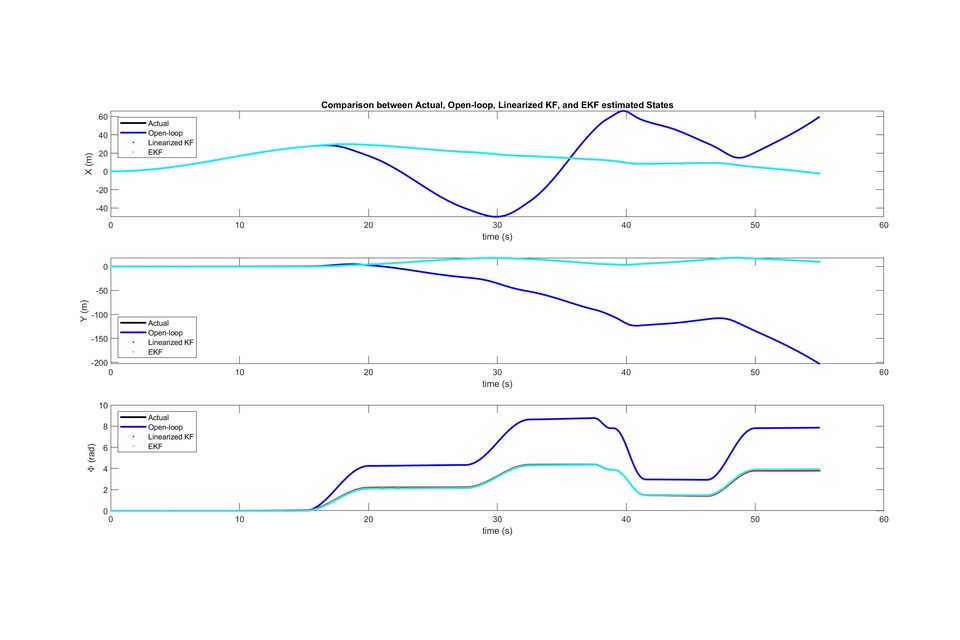
Position and Orientation Estimation of an RC Car Using Kalman Filtering
Modeled and simulated RC-car dynamics in MATLAB to estimate vehicle position and orientation.
Implementation Designed Kalman and extended Kalman filters for the simulated vehicle, with estimation-error and state-comparison plots.
Embedded Systems & Mechatronics
Feb. 2022 – Sep. 2022
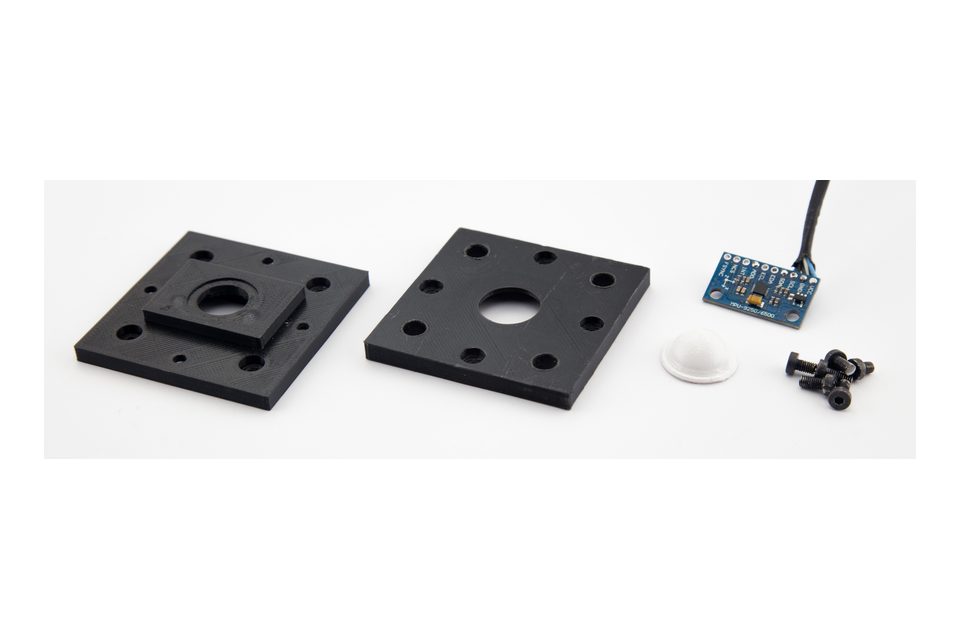
Design and Fabrication of a Soft Magnetic Tactile Sensor
Designed and fabricated a Hall-effect-based soft tactile sensor, from dome deformation analysis and 3D-printed prototyping to Arduino-based data acquisition.
Prototype Fabricated a Hall-effect-based tactile sensor and implemented a multi-layer perceptron that predicts applied force from Hall-effect signals.
Feb. 2022 – Sep. 2022
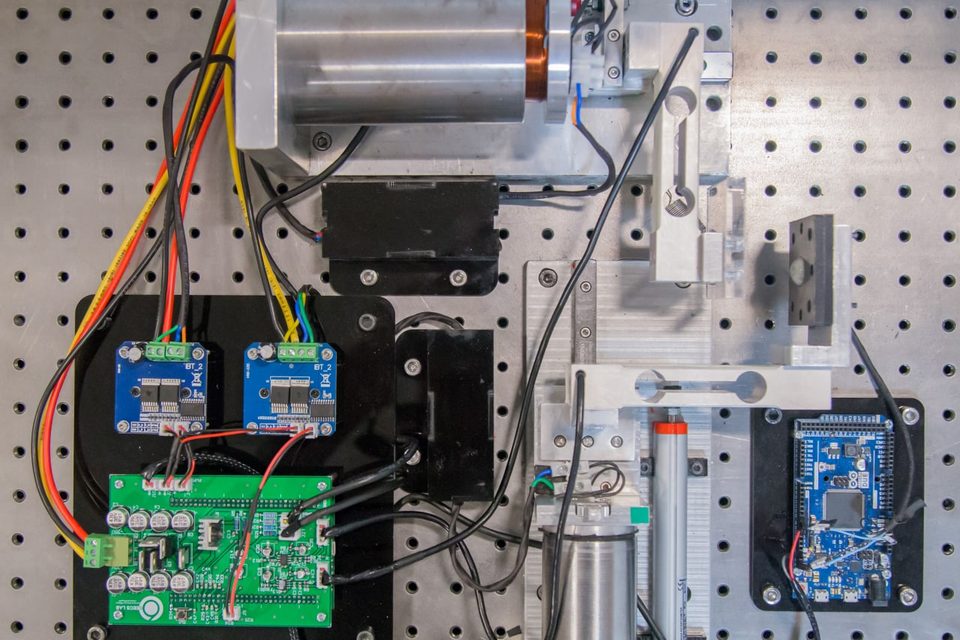
Test Rig Design for Tactile Sensor
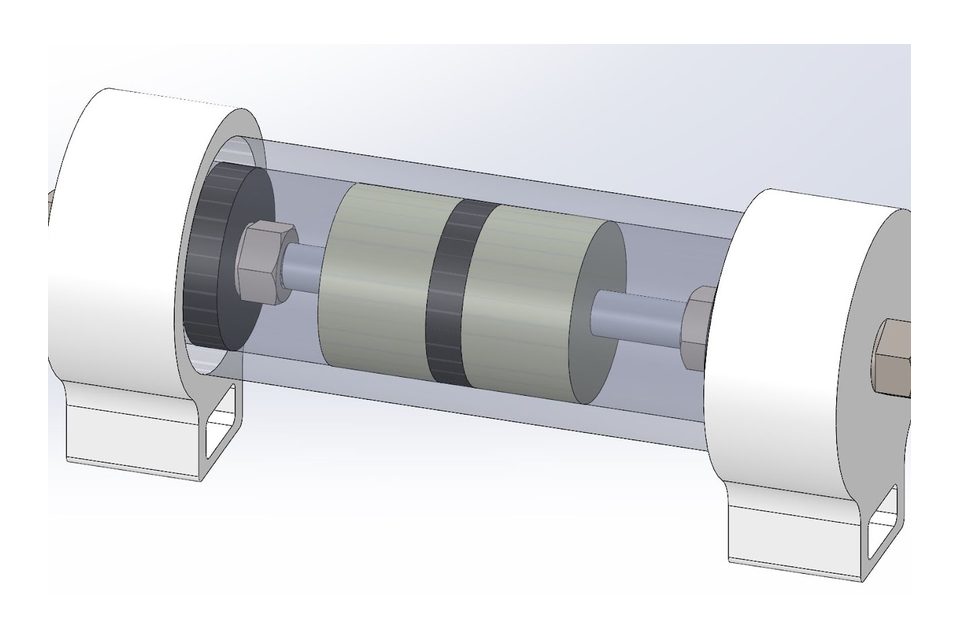
Designed a test bed that applies normal and tangential forces to the tactile sensor using two cylindrical linear voice-coil actuators.
Prototype Built the test bed, with signal-conditioning circuitry designed and simulated in Altium and PID control of both voice coils on an STM32.
June 2020 – January 2021
Hand Stabilizer Gloves for Parkinson Disease
Designed components of a hand-stabilizer glove for Parkinson disease using SOLIDWORKS and design optimization.
Design A passive vibration absorber with a magnetic spring, and a vibrating shaft designed to simulate Parkinson tremors.
Summer 2021
Macro-Atomic Force Microscopy
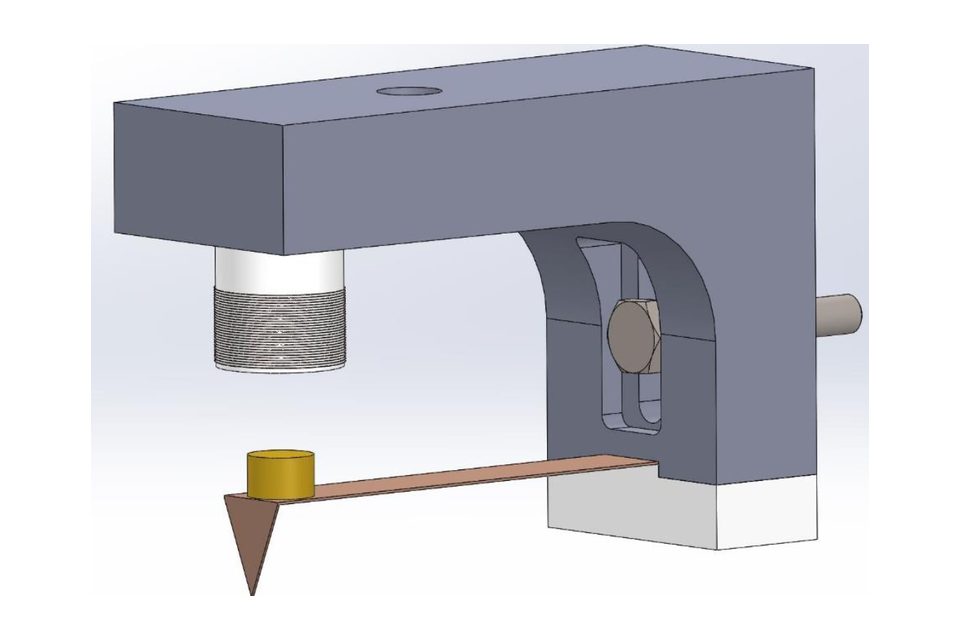
Internship project on modeling a macro-scale atomic force microscopy (macro-AFM) probe.
Analysis Modeled and analyzed the probe (mechanical + magnetic) in ANSYS and studied its frequency response and feedback.
Research Leadership
April 2025 – Present
CORE Lab Vehicle Trajectory Prediction Team
Mentoring an undergraduate team developing ML models for interactive vehicle behavior prediction in multi-agent environments.
Mentorship Guiding the team's data processing, training pipelines, and model validation.
2023 – 2025
F1Tenth Autonomous Racing Platform
Co-supervised and co-developed the CORE Lab's F1tenth autonomous racing platform.
Technical Leadership Established repeatable calibration/validation procedures and guided an undergraduate team through hardware bring-up, instrumentation, and testing.